Liangjun Xing

Intro

Biography

I am a third-year Master's student in the Department of Automation at Tsinghua University, advised by Prof. Yebin Liu in the BBNC Lab, after receiving my bachelor's degree in Automation from Xi'an Jiaotong University. I am currently interning at the Robbyant team at Ant Group, mentored by Dr. Lin Li and Prof. Yinghao Xu. Previously, I interned at Shanghai AI Lab and worked closely with Dr. Kailin Li and Jingbo Wang. I am currently looking for 2027 job and PhD opportunities. Feel free to reach out by email if you would like to discuss research, collaboration, or future opportunities.

Interests

  • Humanoid loco-manipulation (RL Controller + VLA)
  • Dexterous hand manipulation
  • Mixture of various kinds of data in VLA training
  • 3D-native WAM with spatial memory

My long-term goal is to become a full-stack robotics researcher and engineer building humanoid autonomous systems for home environments.

Selected Projects

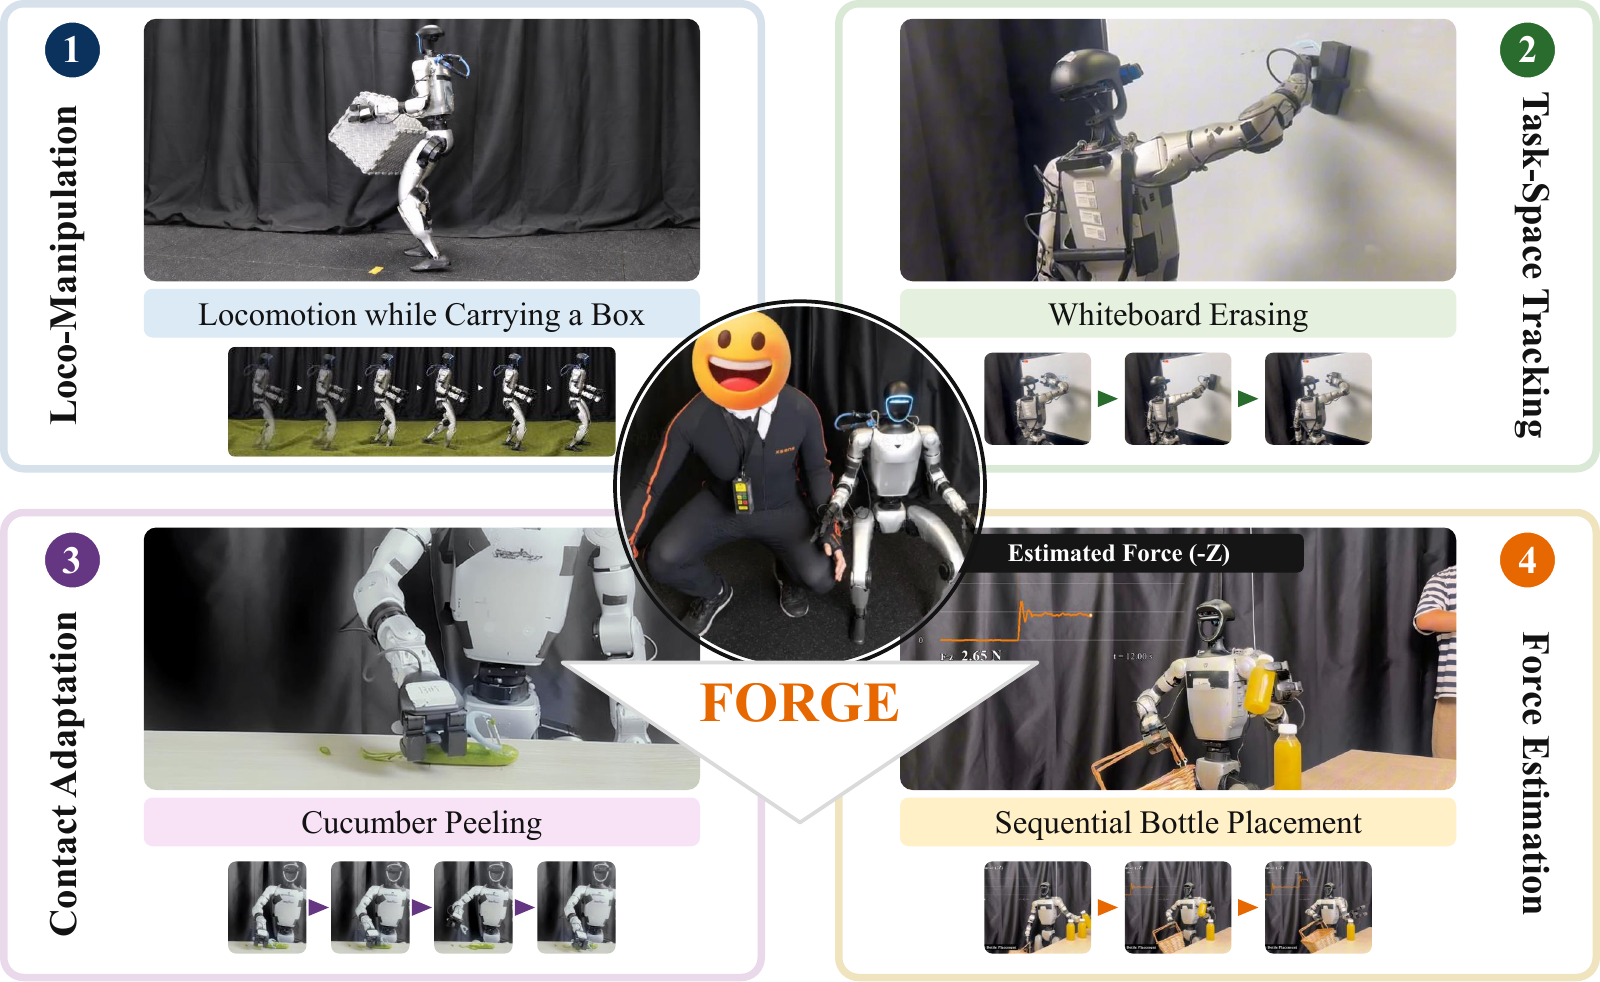
FORGE: Force-Aware Multi-Granularity Control for Efficient Humanoid Loco-Manipulation

FORGE system overview: loco-manipulation, task-space tracking, contact adaptation, and force estimation

A unified task-space framework for humanoid loco-manipulation, combining multi-granularity commands, a locomotion prior with residual whole-body control, sensorless quasi-static wrist-force estimation, and downstream autonomous policy execution.

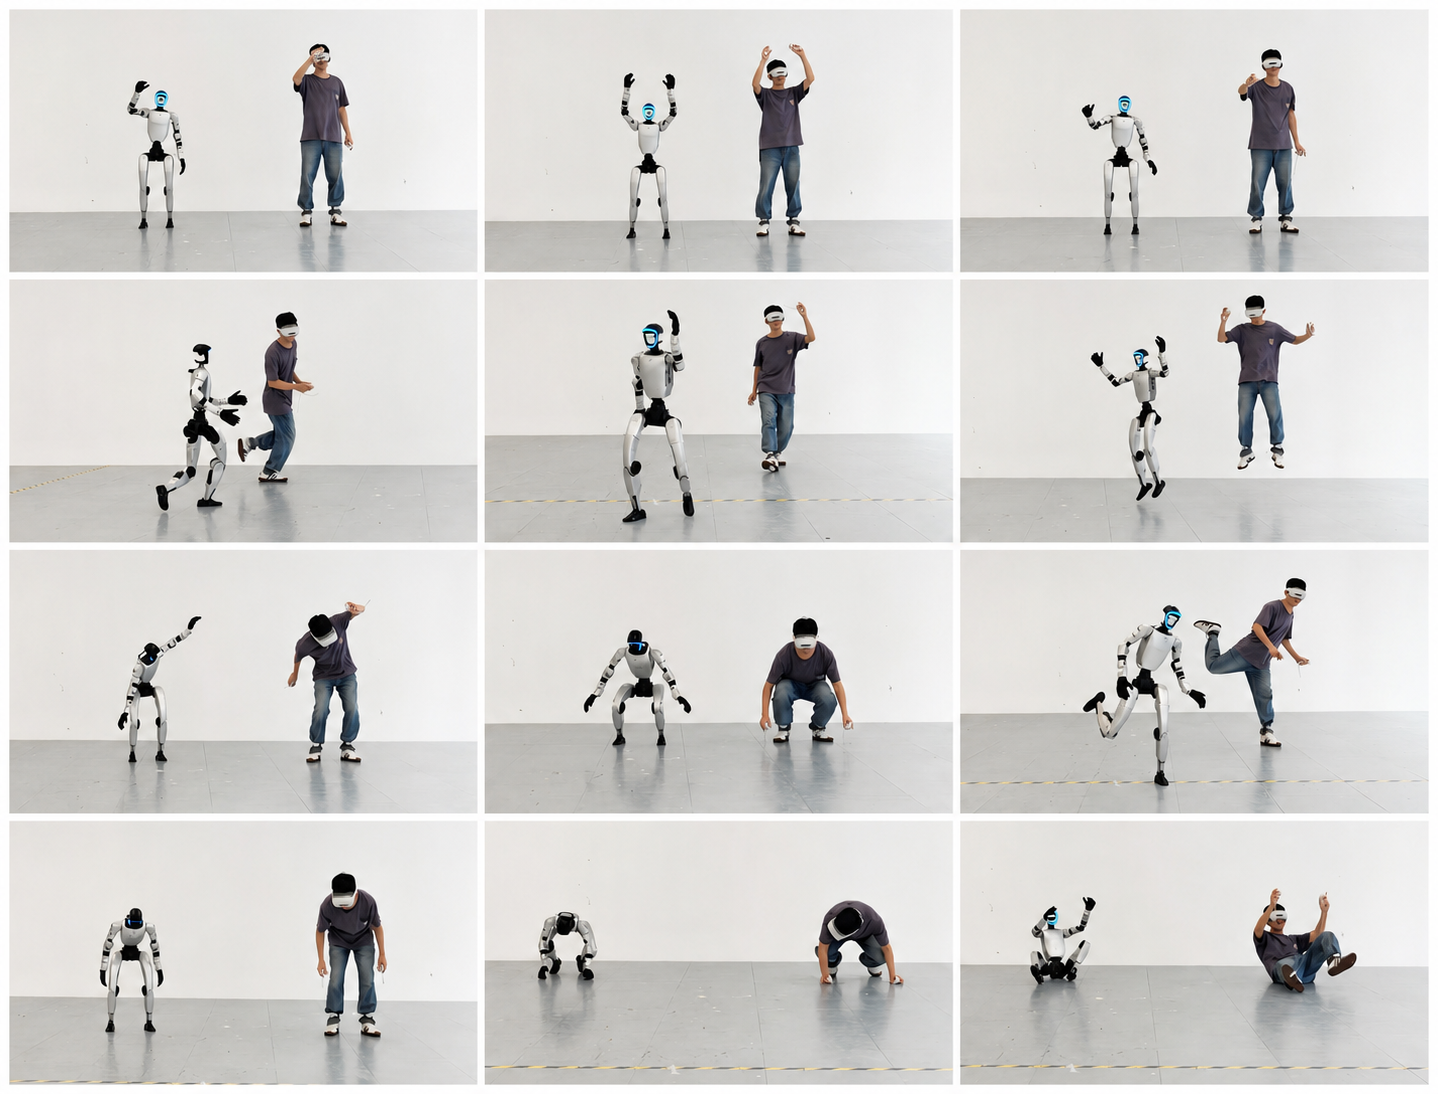
PHT: Predictive Whole-Body Humanoid Teleoperation

PHT whole-body teleoperation: paired human and humanoid poses across gestures, locomotion, jumping, and contact-rich motions

A predictive whole-body teleoperation framework that generates future robot-reference horizons from causal human observations and executes them with a generalist motion tracker. Combines flow-based retargeting, cluster-balanced training, and a residual mixture-of-experts tracker for low-latency teleoperation and autonomous loco-manipulation.

Memory in Motion: Learning Memory-Based Humanoid Loco-Manipulation from Visual Interaction and Motion

Memory in Motion teaser: joint learning from motion and interaction, motion-conditioned memory writing, and long-horizon humanoid loco-manipulation

A motion-conditioned memory architecture for humanoid loco-manipulation. It uses current observations, body motion, and prior memory to select recent evidence and update a compact recurrent state, helping policies retain task-relevant information as the robot moves and its viewpoint changes.

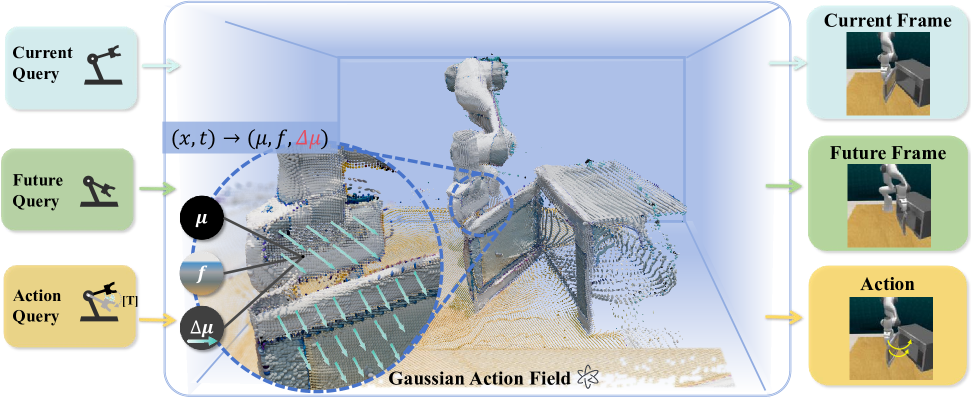
GAF: Gaussian Action Field as a 4D Representation for Dynamic World Modeling in Robotic Manipulation

GAF figure 1

Proposed a V-4D-A framework with Gaussian Action Field for direct action inference, showing bi-manual dexterous manipulation capability in RLBench tasks and real-world deployment. Achieved +11.54 dB PSNR improvement and boosted robotic task success rate by 10.33% over SOTA methods.

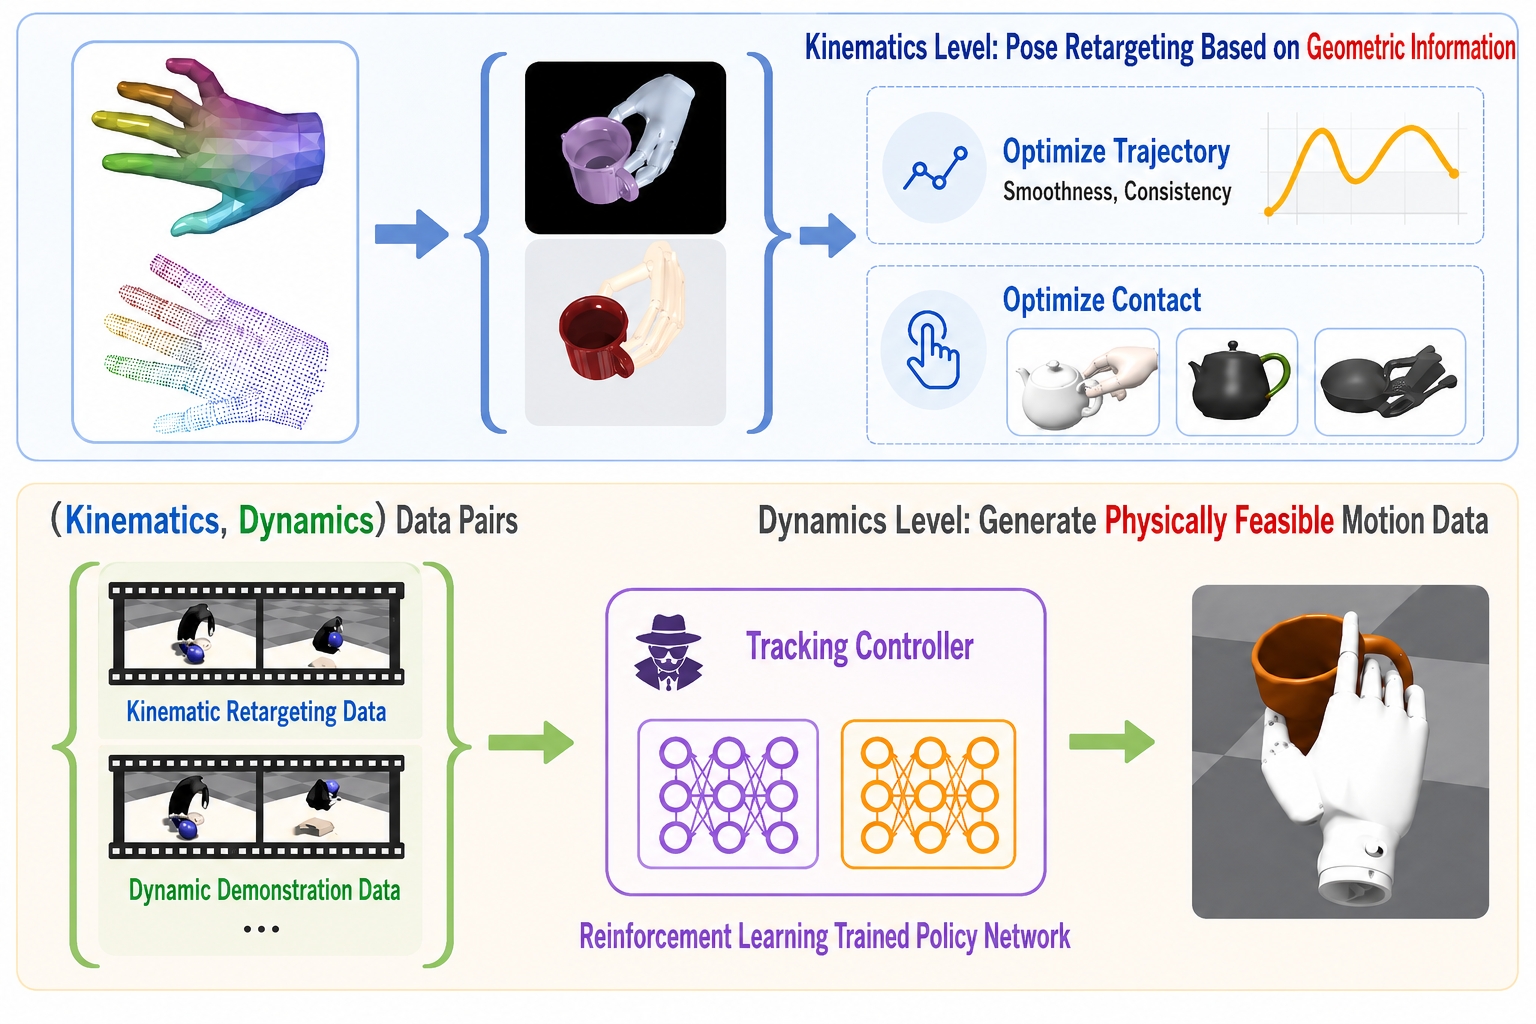
Motion Tracking Methods for Dexterous-Hand Manipulation

Motion Tracking

Optimized the retargeting pipeline from MoCap data to dexterous-hand interactions, designed RL reward functions for articulated object manipulation, addressed task expansion via policy distillation, and adapted motion generation to various dexterous hands.

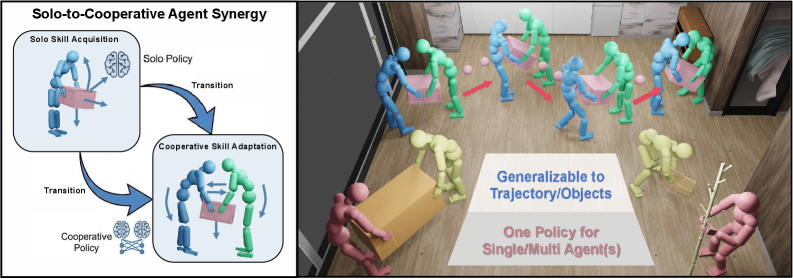
SynAgent: Generalizable Cooperative Humanoid Manipulation via Solo-to-Cooperative Agent Synergy

SynAgent figure 1

A framework for generalizable cooperative humanoid manipulation, enabling synergy from solo-agent training to cooperative multi-agent deployment for complex manipulation tasks.
Experiences

Education

Tsinghua University

– Present

Master's Student · Department of Automation

Advised by Prof. Yebin Liu in the BBNC Lab. Research on humanoid loco-manipulation and dexterous-hand manipulation.

Xi'an Jiaotong University

–

B.Eng. in Automation

Courses in control theory, robotics, deep learning, and computer vision.

Research & Industry

Robbyant Team in Ant Group

– Present

Research Intern

Mentored by Dr. Lin Li and Prof. Yinghao Xu.

Research on memory-augmented humanoid VLA policies and predictive whole-body teleoperation, including Memory in Motion and PHT.

Shanghai Artificial Intelligence Laboratory

–

Research Intern

Mentored by Dr. Kailin Li and Dr. Jingbo Wang.

Developed FORGE for force-aware whole-body control and teleoperation, alongside multimodal data collection and high-level diffusion and VLA policies.

Unitree Robotics

–

Robotics Intern · Tsinghua THMOS RoboCup Team

Worked on humanoid soccer decision-making, fall recovery, and 2-DoF visual ball tracking. The team placed fourth at RoboCup 2025 in Brazil.

Misc.

I have broad interests beyond research. I enjoy Chinese classical poetry and costume dramas, and I love listening to Mandopop, especially Stefanie Sun. I also enjoy playing piano, singing, photography, aerobic exercise, and traveling.